Welcome to KineJing.

Some are bornto move the worldand bring their dreamsto life.

World-model data,built for embodied intelligence.

Make imagination possiblein the physical world.

Our vision: machines that understand the world, anticipate change, and turn ideas into action.

WORLD MODELS / EMBODIED DATA

World-model interaction data

Aligned observations, actions and next observations, with reproducible collection, validation and custom delivery for world-model and embodied AI teams.

WM Interaction v1: 12,000 episodes · 818,161 transitions · 3 simulation subsets. Every episode file matches by SHA256 across two independent full collections.

Schema, license and validation scope ↗

01 / DEMONSTRATIONS

Watch the world change.

Open research gallery ↗

Real arm recordings, motion analysis and environment execution. Every demonstration has a source and a reproducible record.

01 / ROBOT OBSERVATION

One recording. Three perspectives.

Recorded Panda arm: two exterior cameras and a wrist camera, synchronized over 16 seconds and 240 frames per view.

DROID / NVIDIA Cosmos recording; KineJing synchronization audit and presentation.

Source & reproduction ↗
02 / MOTION DIAGNOSTICS

Make motion measurable.

Actual CPU optical flow on the same arm recording, measuring pixel motion, direction and change over time.

Recorded observation with Farneback diagnostics; not robot control or learned prediction.

Source & reproduction ↗

03 / ENVIRONMENT REPLAY

Replay a released trajectory.

75 released expert actions execute in the official FourRoom environment; 76 ego positions match the released segment.

Upstream expert CPU replay; static distractors and goal termination disabled. Coordinate audit, not pixel identity or model policy.

Source & reproduction ↗

The two arm presentations use the same DROID episode 48330, not two independent trials. Recording: DROID Dataset Team / NVIDIA Cosmos, OpenMDW-1.1. FourRoom reference: the H-JEPA authors, CC BY 4.0. Full attribution & licences ↗

02 / COMPARISONS

Experiments. And their controls.

Protocols & records ↗

Six separate experiments. Each figure keeps its task, baseline and conditions; open a figure or its execution record.

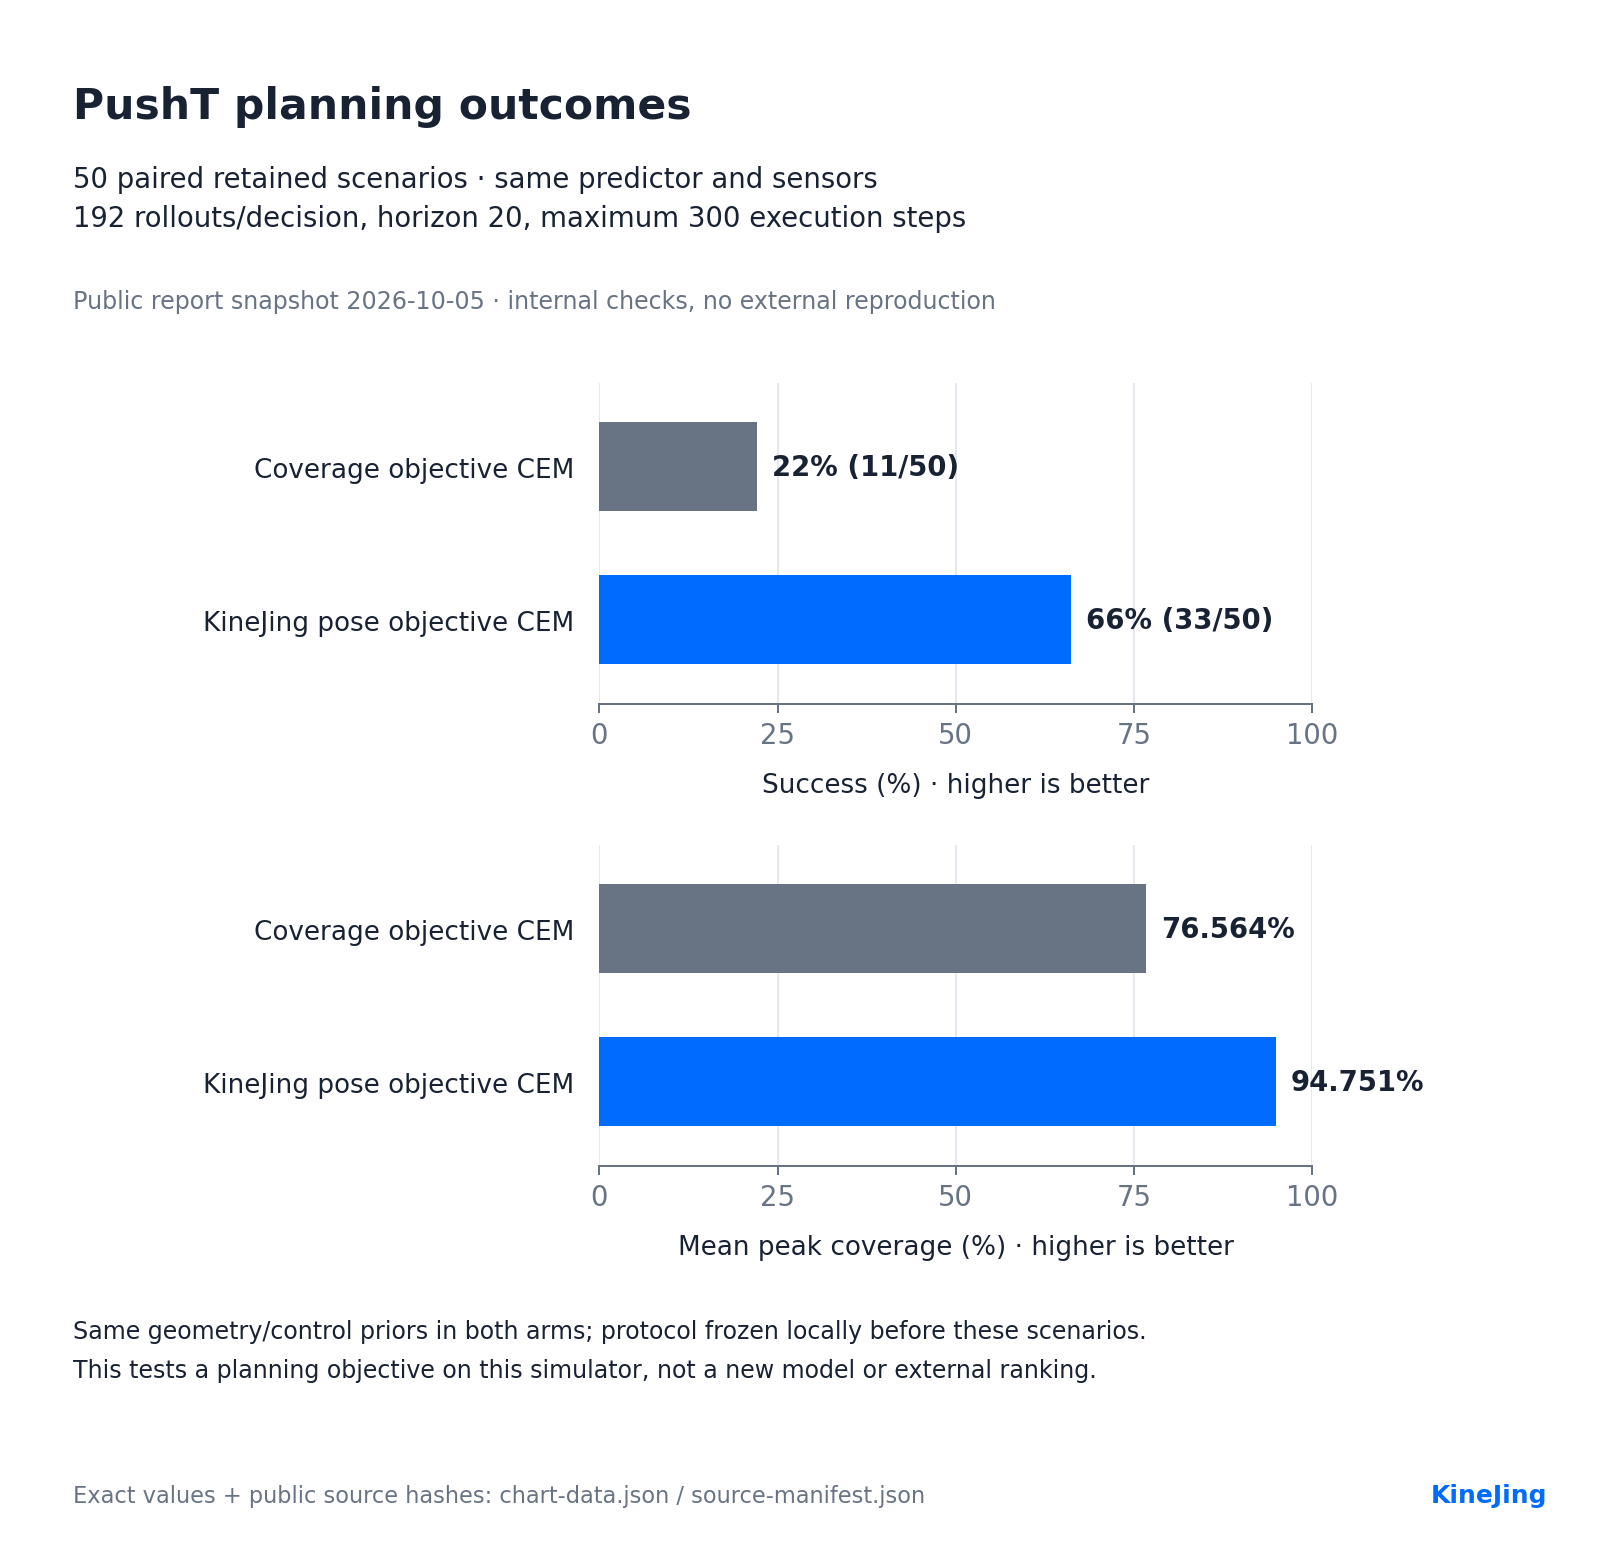
PushT · 50 paired scenarios: Pose objective 33/50; coverage objective 11/50. Matched predictor, sensors and per-decision budget; this simulation protocol only.

01 / PushT · 50 paired scenarios

Same predictor. Different planning objectives.

Pose objective 33/50; coverage objective 11/50. Matched predictor, sensors and per-decision budget; this simulation protocol only.

Execution record ↗
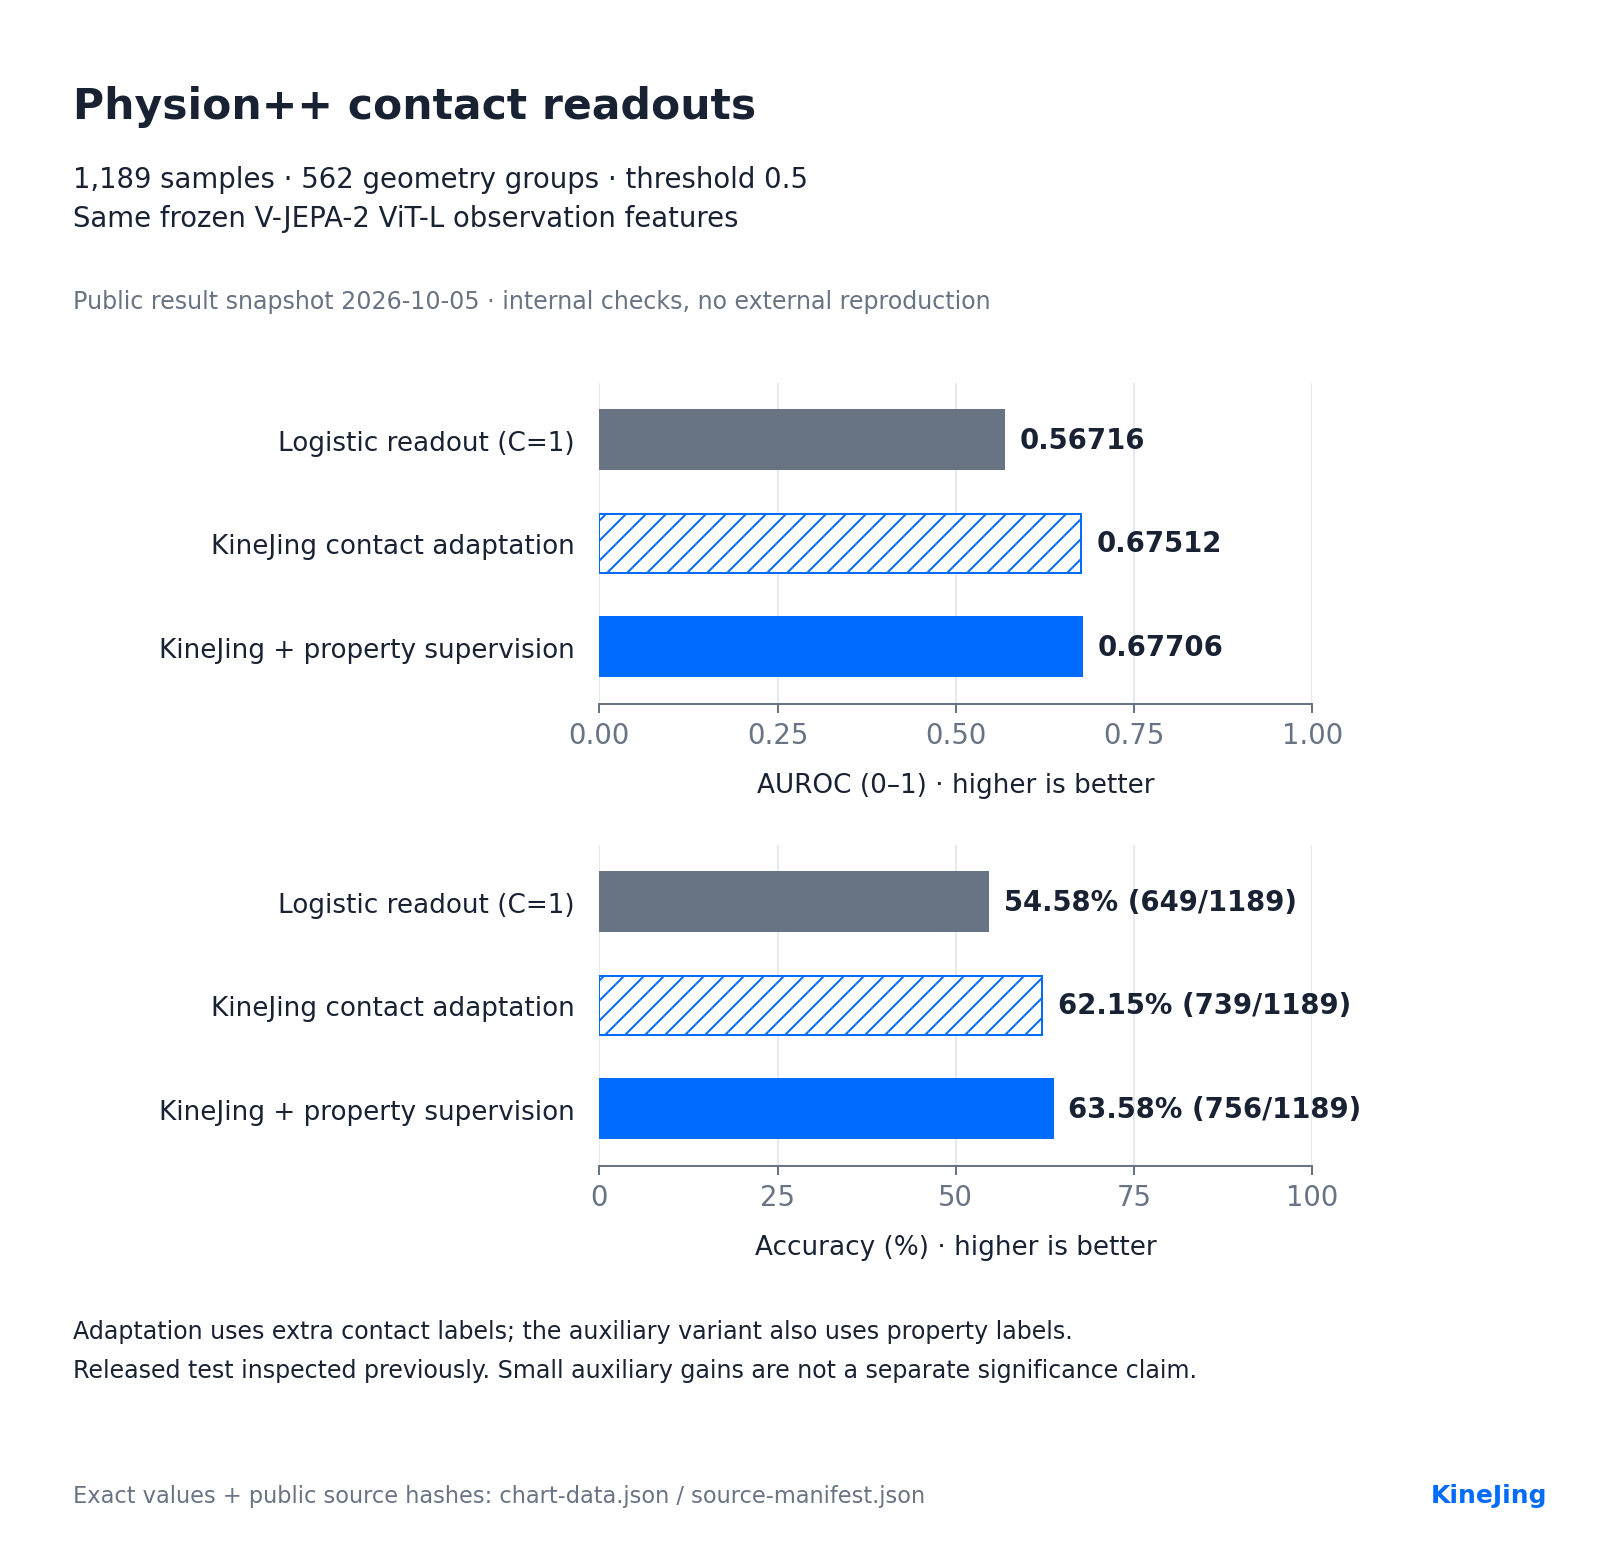
Physion++ · Frozen-feature readouts: 1,189 samples, frozen V-JEPA-2 features, with added task and property supervision. The test was previously inspected: re-evaluation, not a new blind test.

02 / Physion++ · Frozen-feature readouts

Contact prediction from frozen features.

1,189 samples, frozen V-JEPA-2 features, with added task and property supervision. The test was previously inspected: re-evaluation, not a new blind test.

Execution record ↗
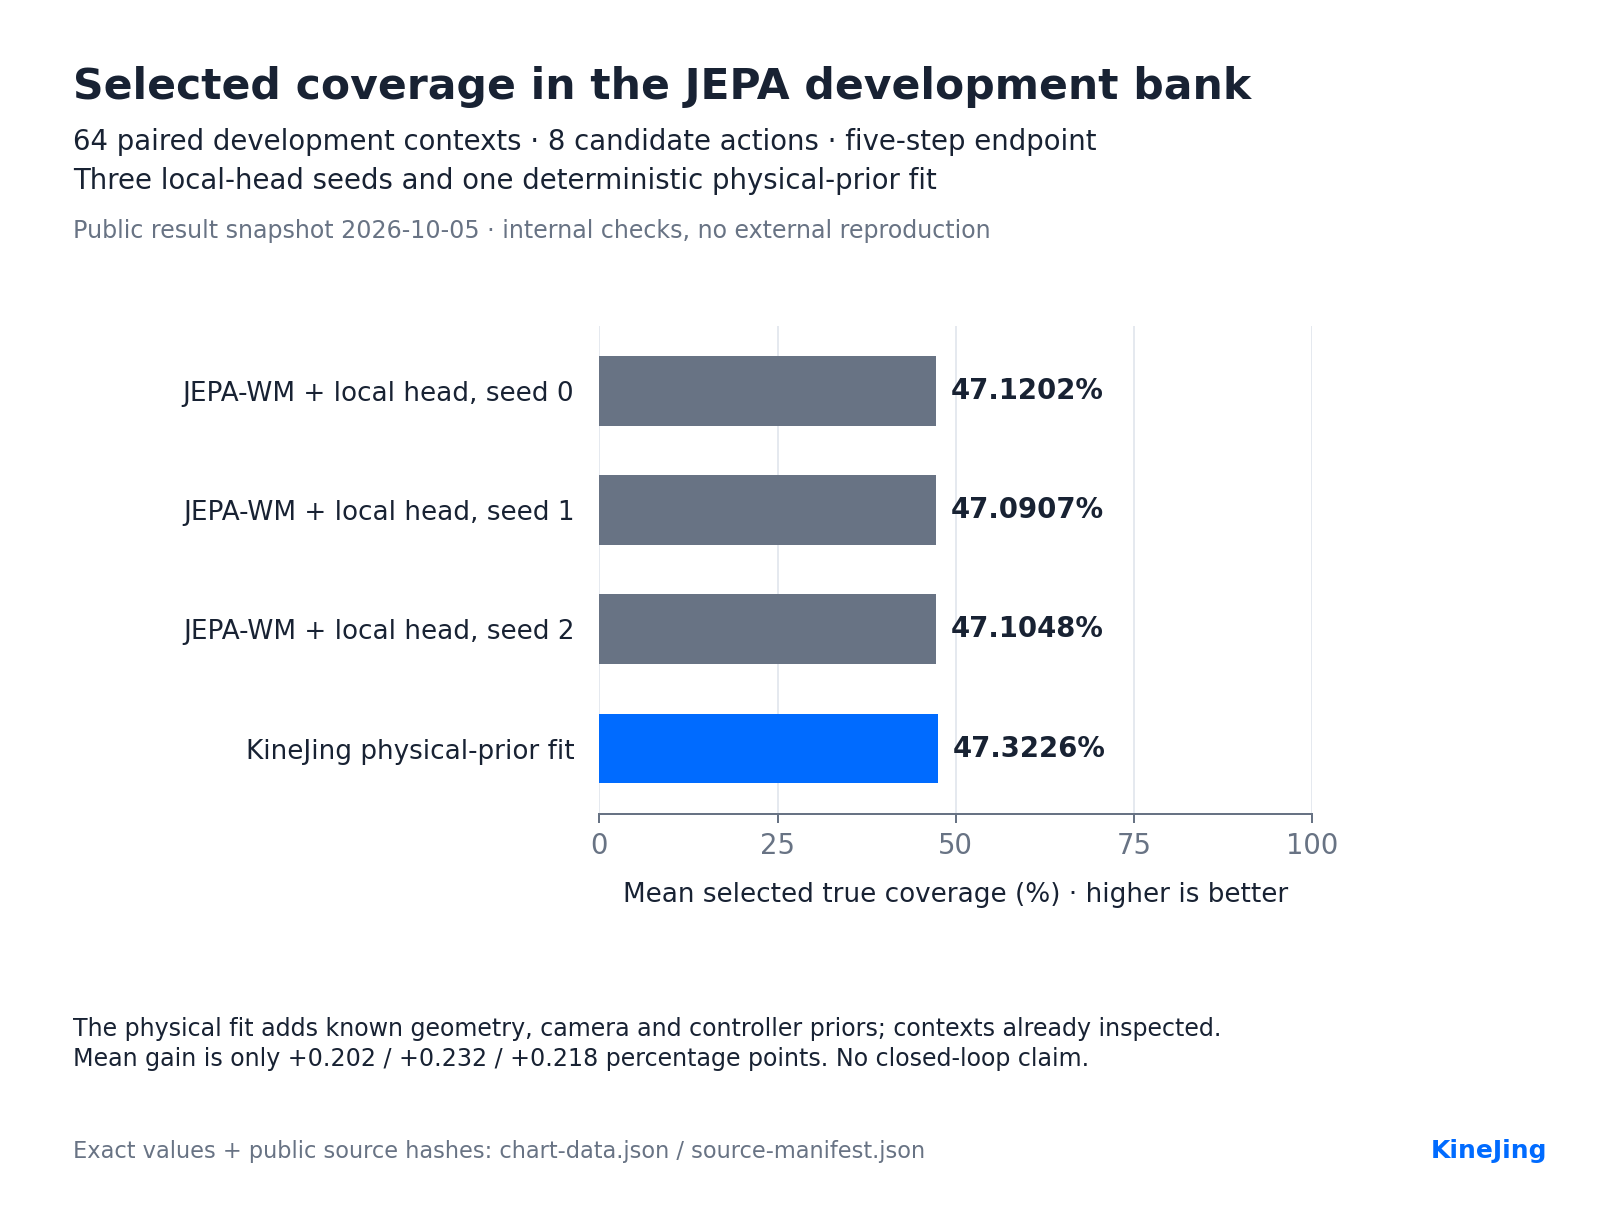
JEPA · Development contexts: 64 development contexts, including three local JEPA-head seeds and physical-prior configurations; not an independent blind test.

03 / JEPA · Development contexts

Candidate selection on development contexts.

64 development contexts, including three local JEPA-head seeds and physical-prior configurations; not an independent blind test.

Execution record ↗
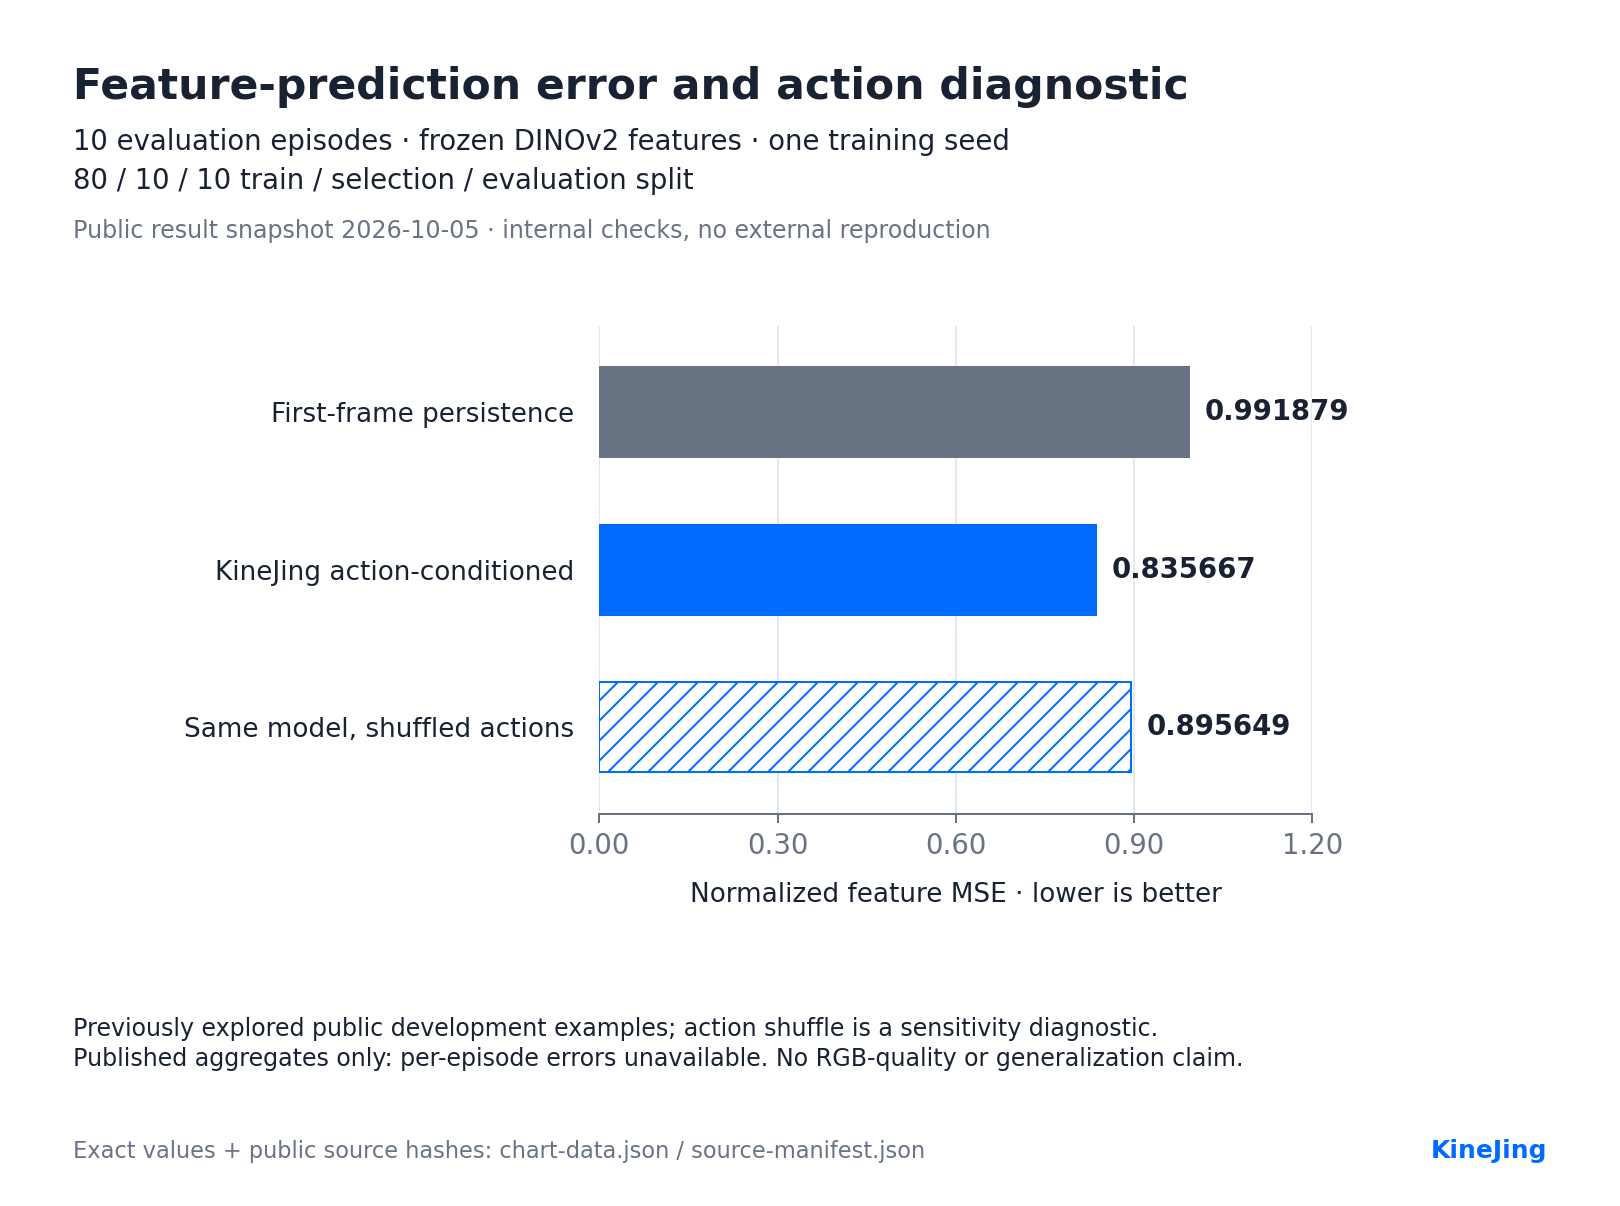
Feature prediction · Action diagnostic: Normalized MSE on frozen DINOv2 features, with persistence and shuffled-action controls; a feature-level diagnostic.

04 / Feature prediction · Action diagnostic

Action-conditioned feature prediction.

Normalized MSE on frozen DINOv2 features, with persistence and shuffled-action controls; a feature-level diagnostic.

Execution record ↗
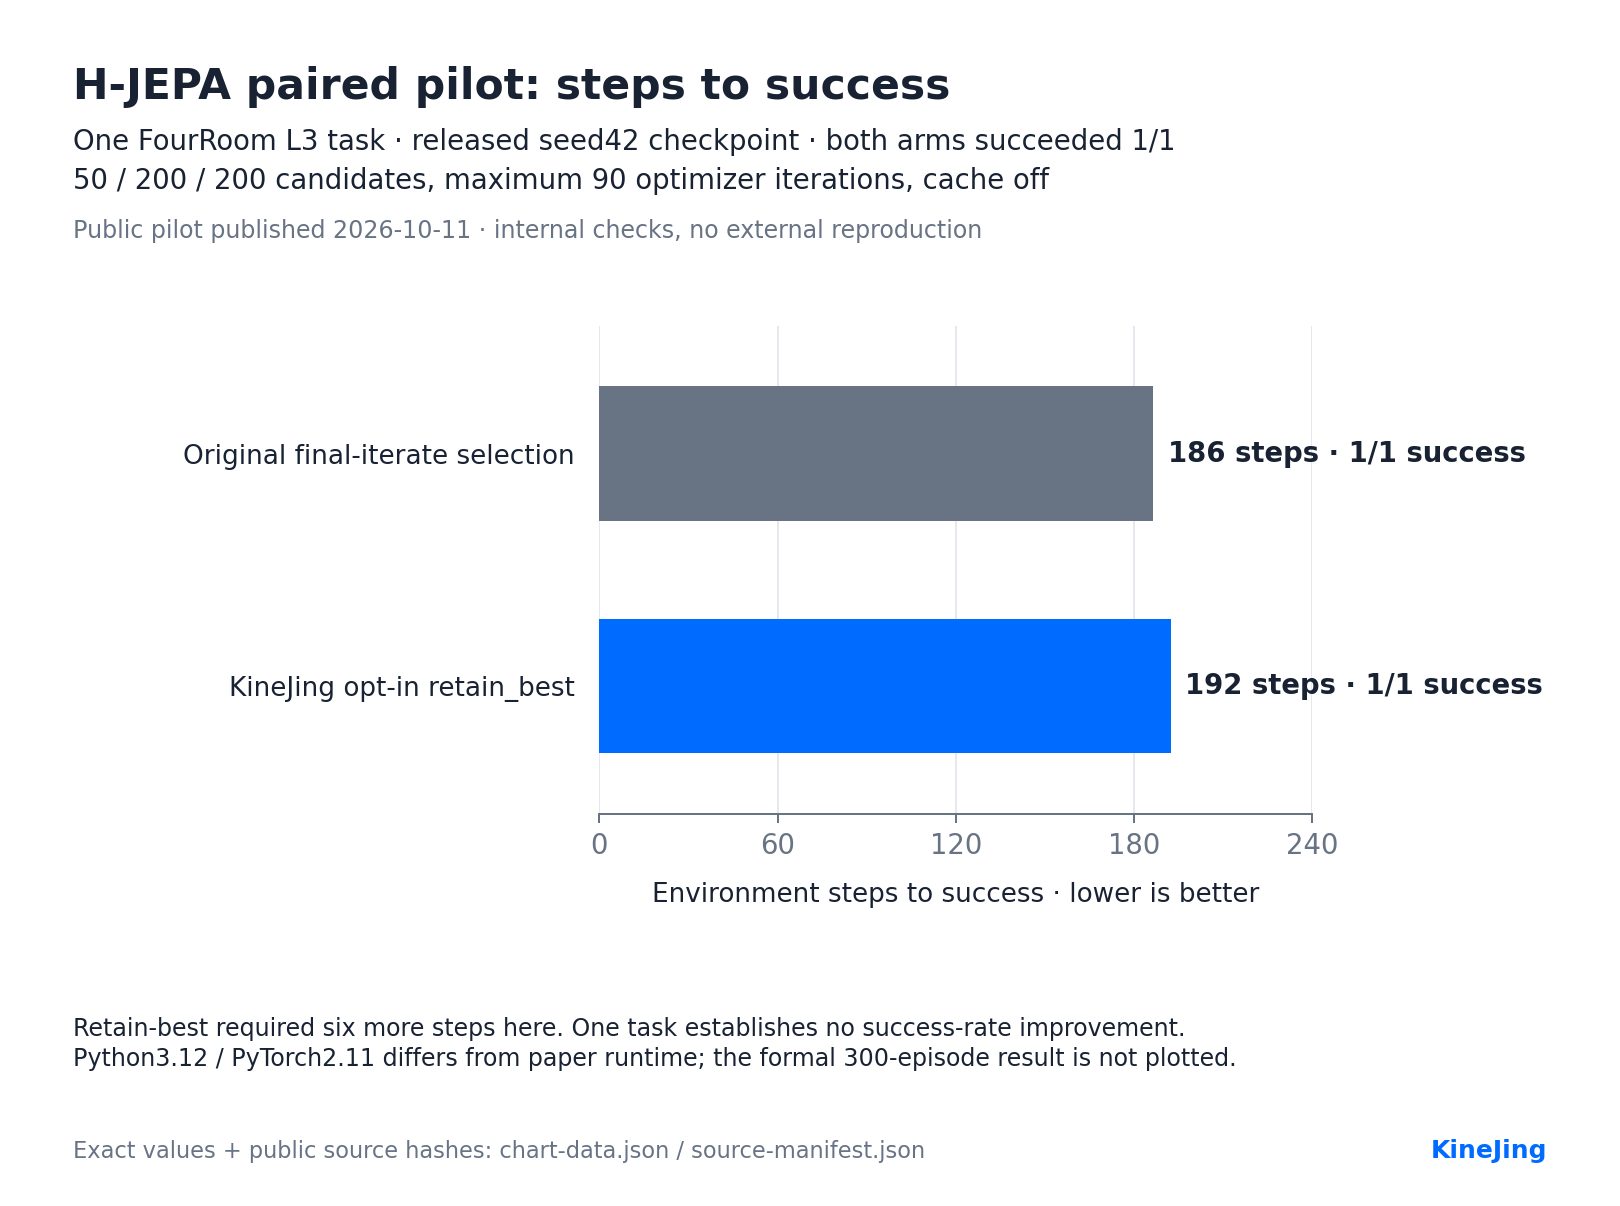
H-JEPA · One matched pilot: Same released L3 weights: baseline 186 steps; retain-best 192; both succeed 1/1. This pilot does not show a success-rate gain.

05 / H-JEPA · One matched pilot

A matched pilot, including the tradeoff.

Same released L3 weights: baseline 186 steps; retain-best 192; both succeed 1/1. This pilot does not show a success-rate gain.

Execution record ↗
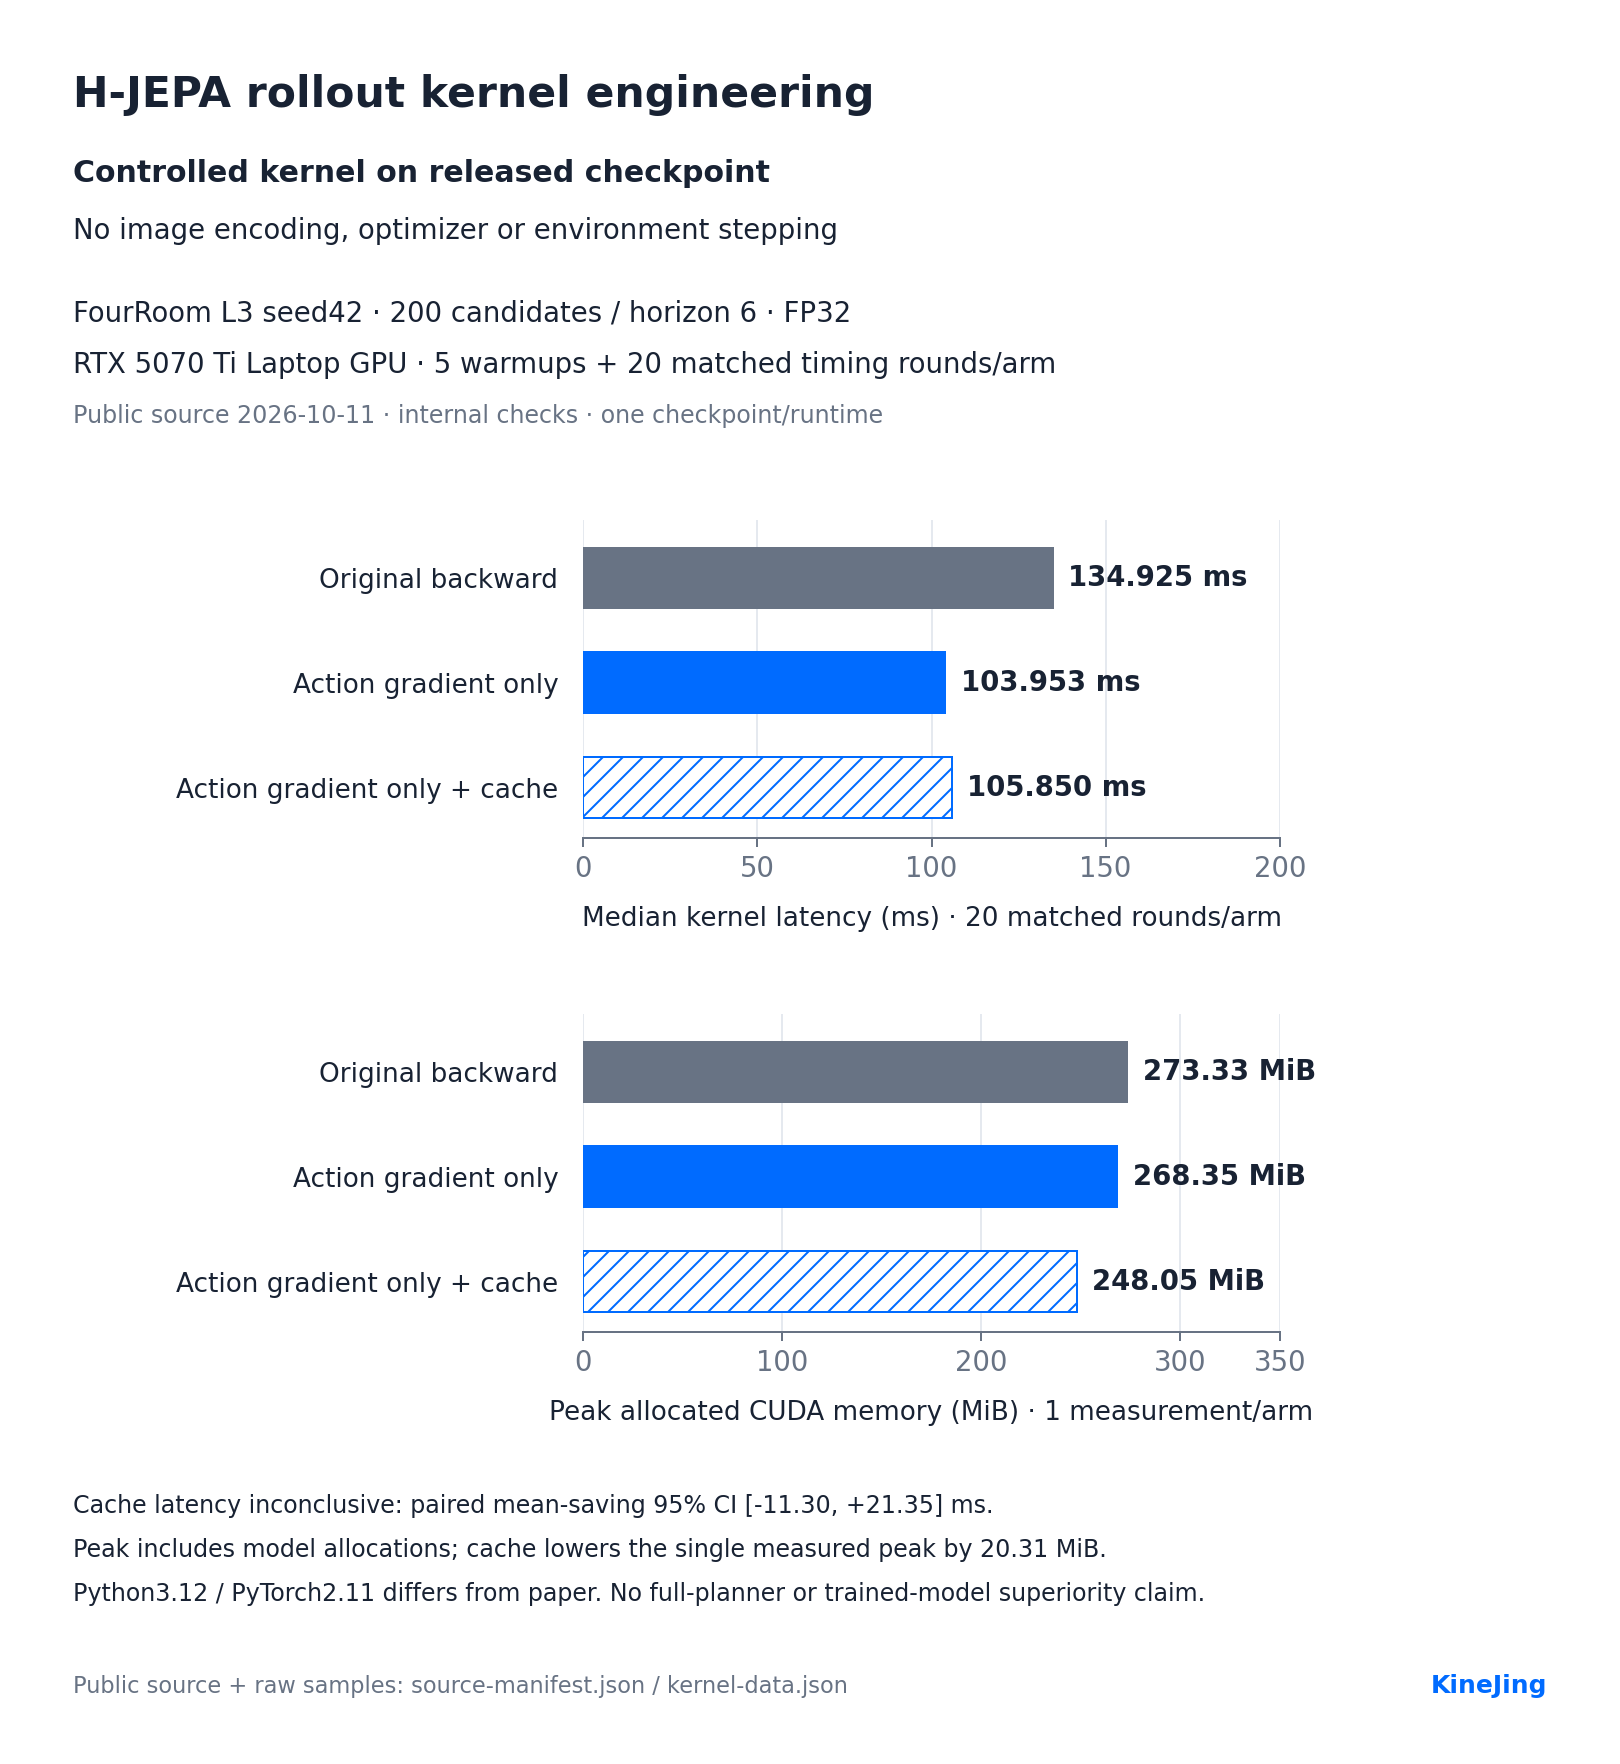
H-JEPA · Controlled L3 kernel: Gradient and cache configurations under a controlled kernel protocol. Kernel timing does not replace end-to-end planning or robot evaluation.

06 / H-JEPA · Controlled L3 kernel

Rollout-kernel latency and memory.

Gradient and cache configurations under a controlled kernel protocol. Kernel timing does not replace end-to-end planning or robot evaluation.

Execution record ↗

03 / RESEARCH MAP

See how the work connects.

Explore research ↗
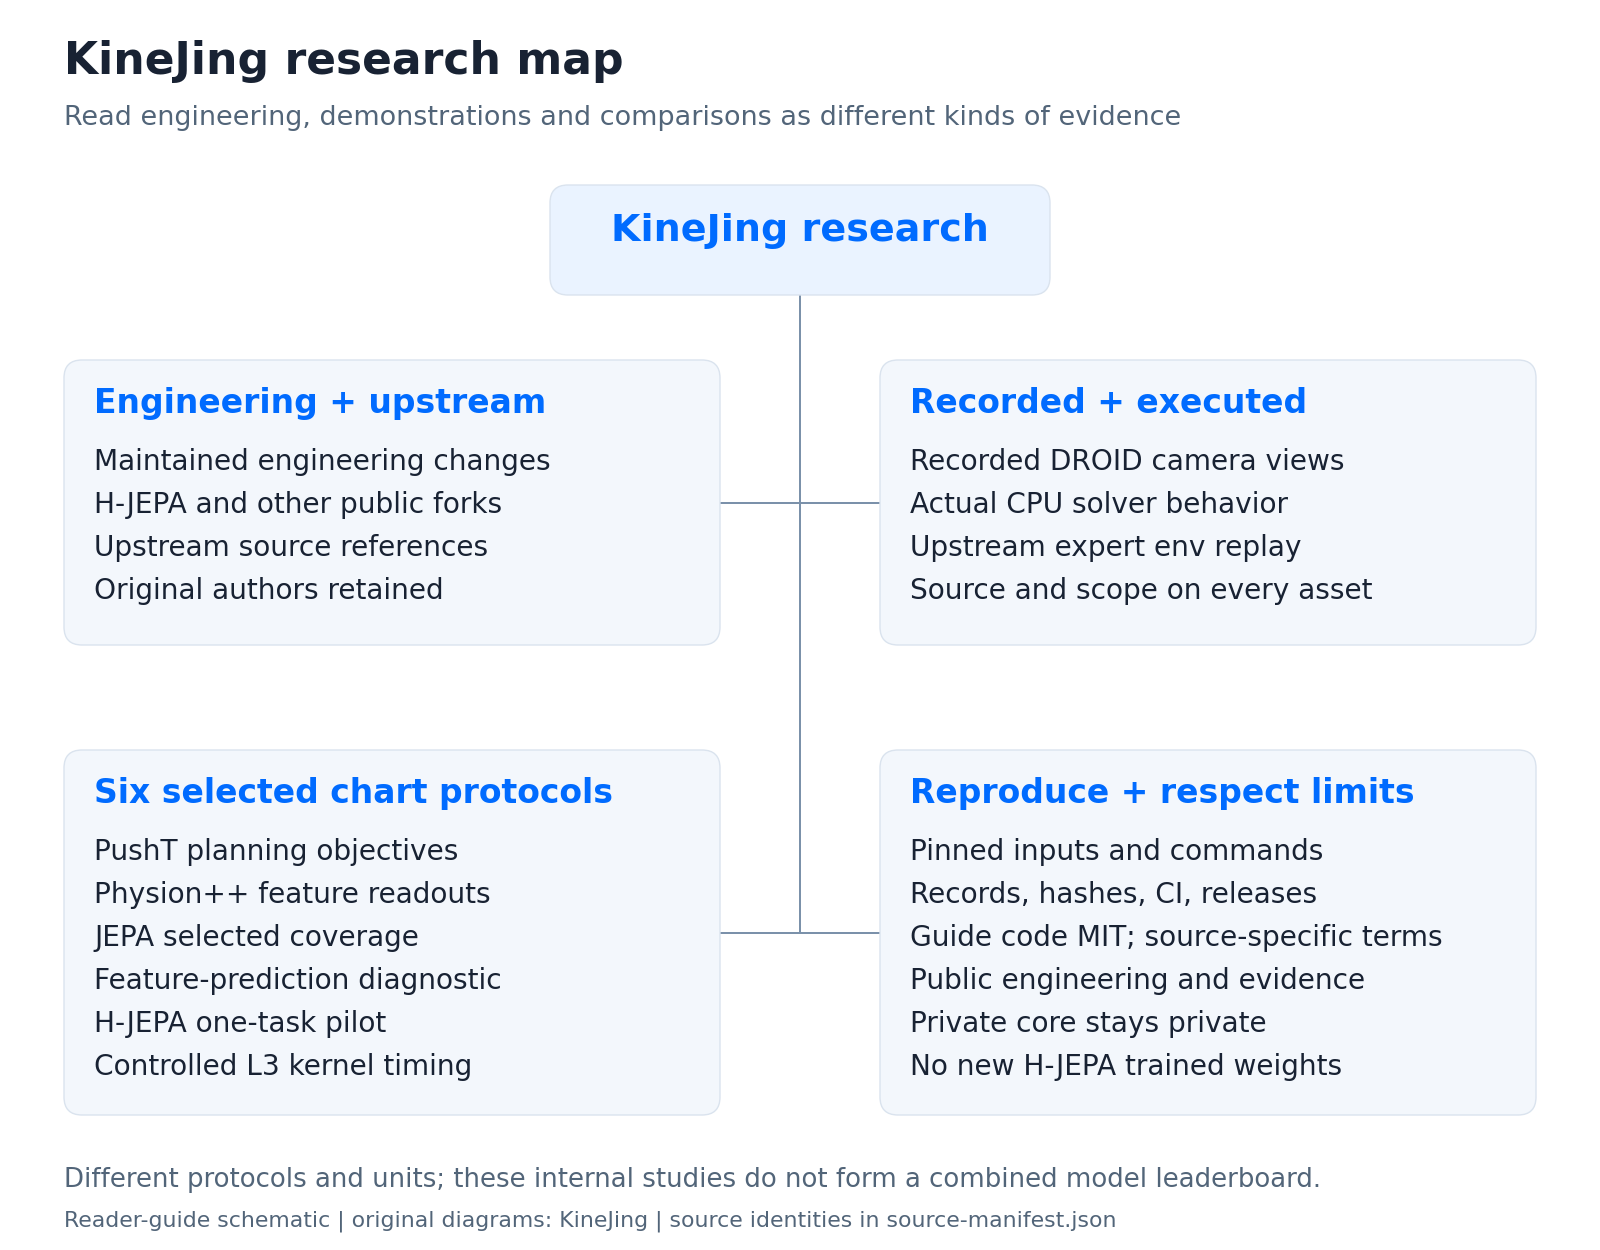
KineJing research map: engineering, recordings, comparisons and reproduction
Research schematic · engineering, demonstrations and experiments connect to their evidence.
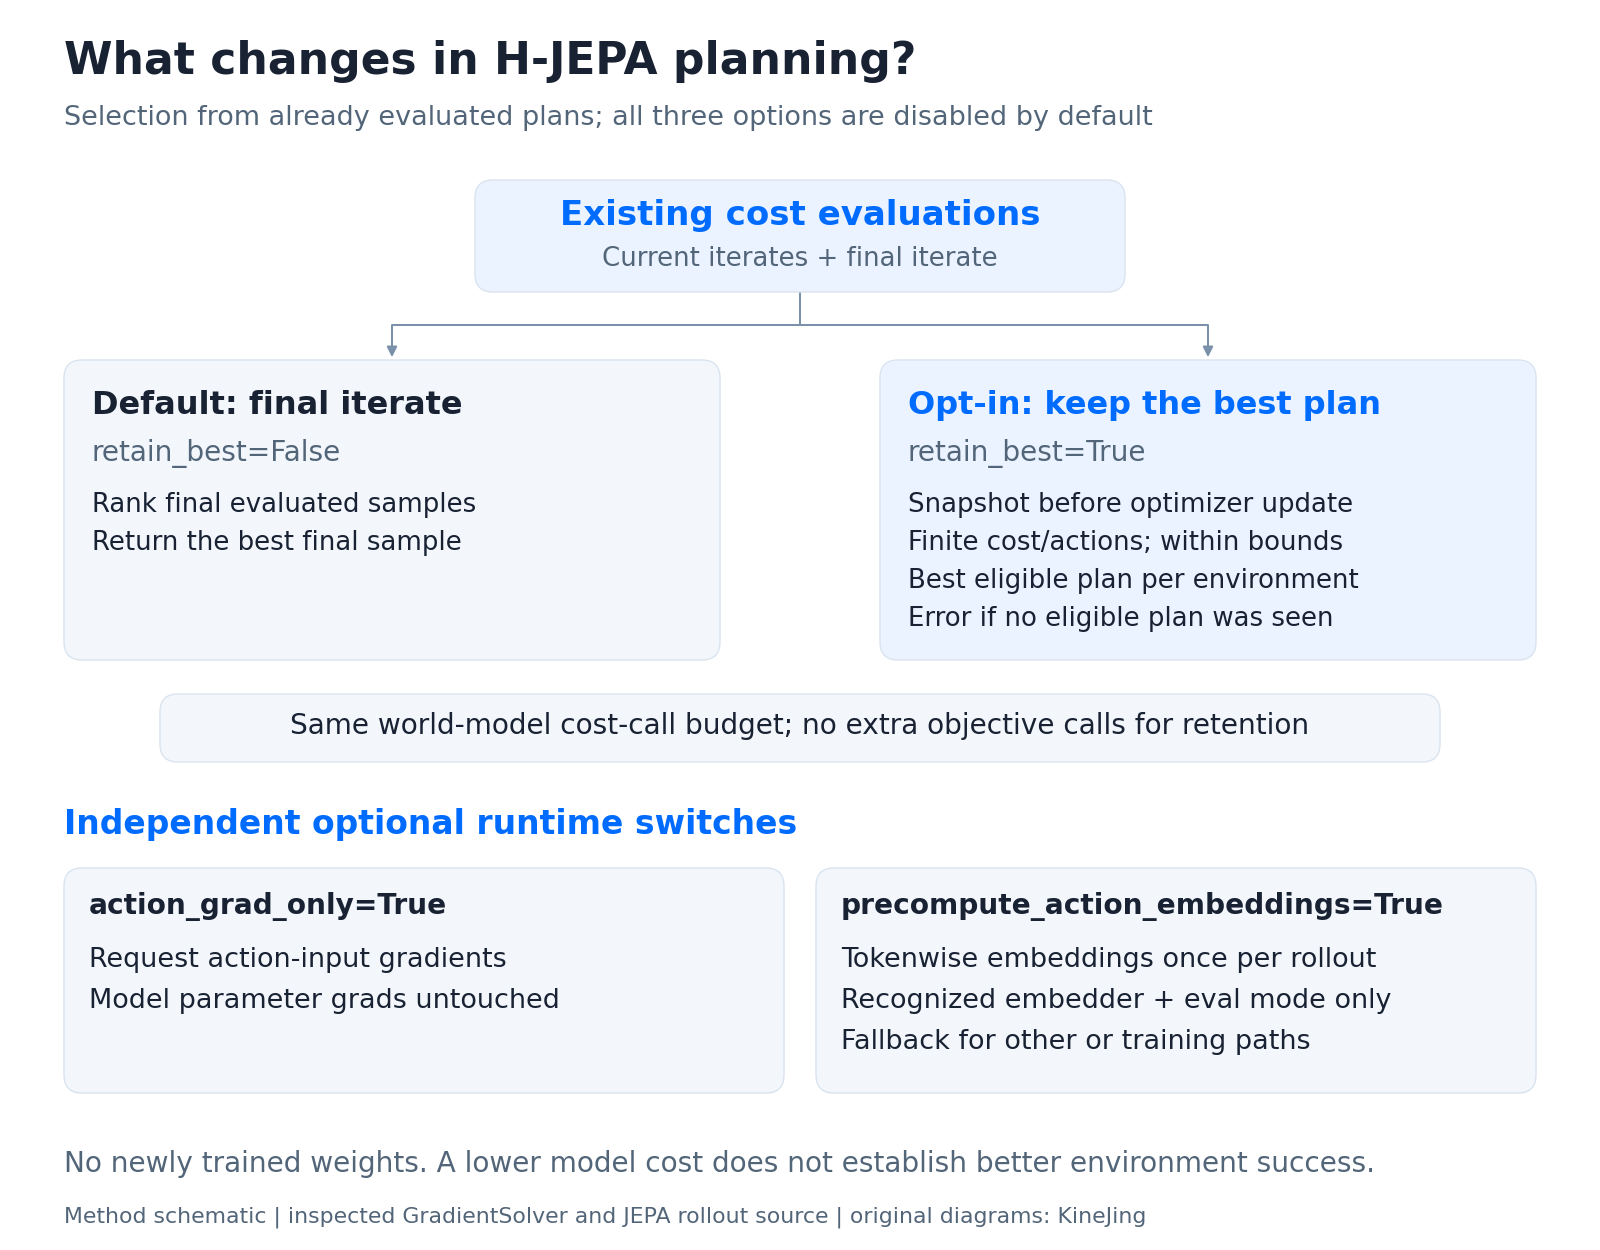
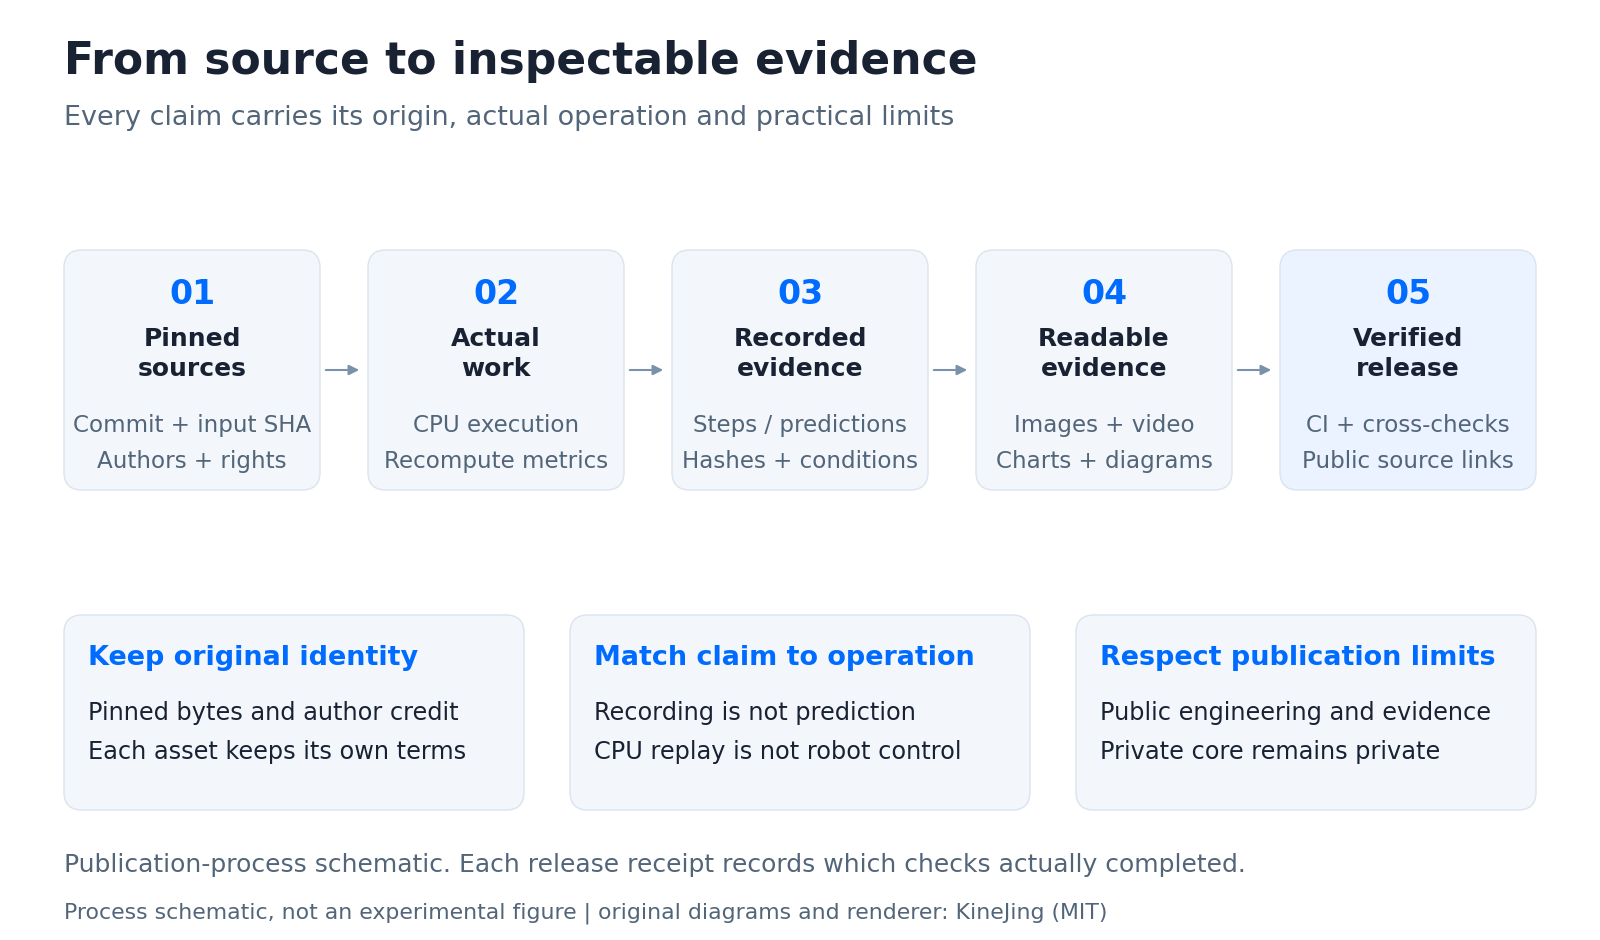
Explore the engineering and experiment diagrams +
H-JEPA optional engineering schematic
H-JEPA engineering
Source to publication evidence schematic
From source to publication

04 / OPEN SOURCE

Open work. New starting points.

Explore all releases ↗

Find code, weights, experiments and paper drafts on Hugging Face. Explore the materials, download them, and reproduce the work.

Per-project licenses apply; some upstream extensions carry noncommercial or other restrictions. Model cards define the scope of research models.

05 / OUR FOCUS

WMEmbodied data

Observation · action · next observation

Interaction data you can reproduce.

Interaction data, validation and custom delivery for world-model and embodied AI teams.

We document observation and action alignment, sample validation, provenance and reproduction conditions.

About KineJing ↗

KINEJING / 勘境

Create new possibilities. Together.

For dataset access, custom collection and delivery requirements, contact us directly.

Email us